Robotics at UMA. Previously founding engineer at k-scale labs (YC W24): first ecosystem of open-source humanoid robots, 200+ units pre-ordered for $2M+.
— why?
machines should add more to the world than they take. people and nature both richer for it, all watched over by machines of loving graceRichard Brautigan.
started as a skunkworks project with two other engineers over winter break, tearing down our old robots to understand why they failed. Four months later it was the company flagship: the first open-source humanoid to deploy RL walking and VLA manipulation, 35 units in the wild.
a 2-ft humanoid for learning RL control. Shipped the first batch fast, watched 70% fail at a hackathon, rebuilt from what we learned. It went on to teach RL at stanford’s CS234, drew a 20k waitlist, and launched at CES.
— other projects
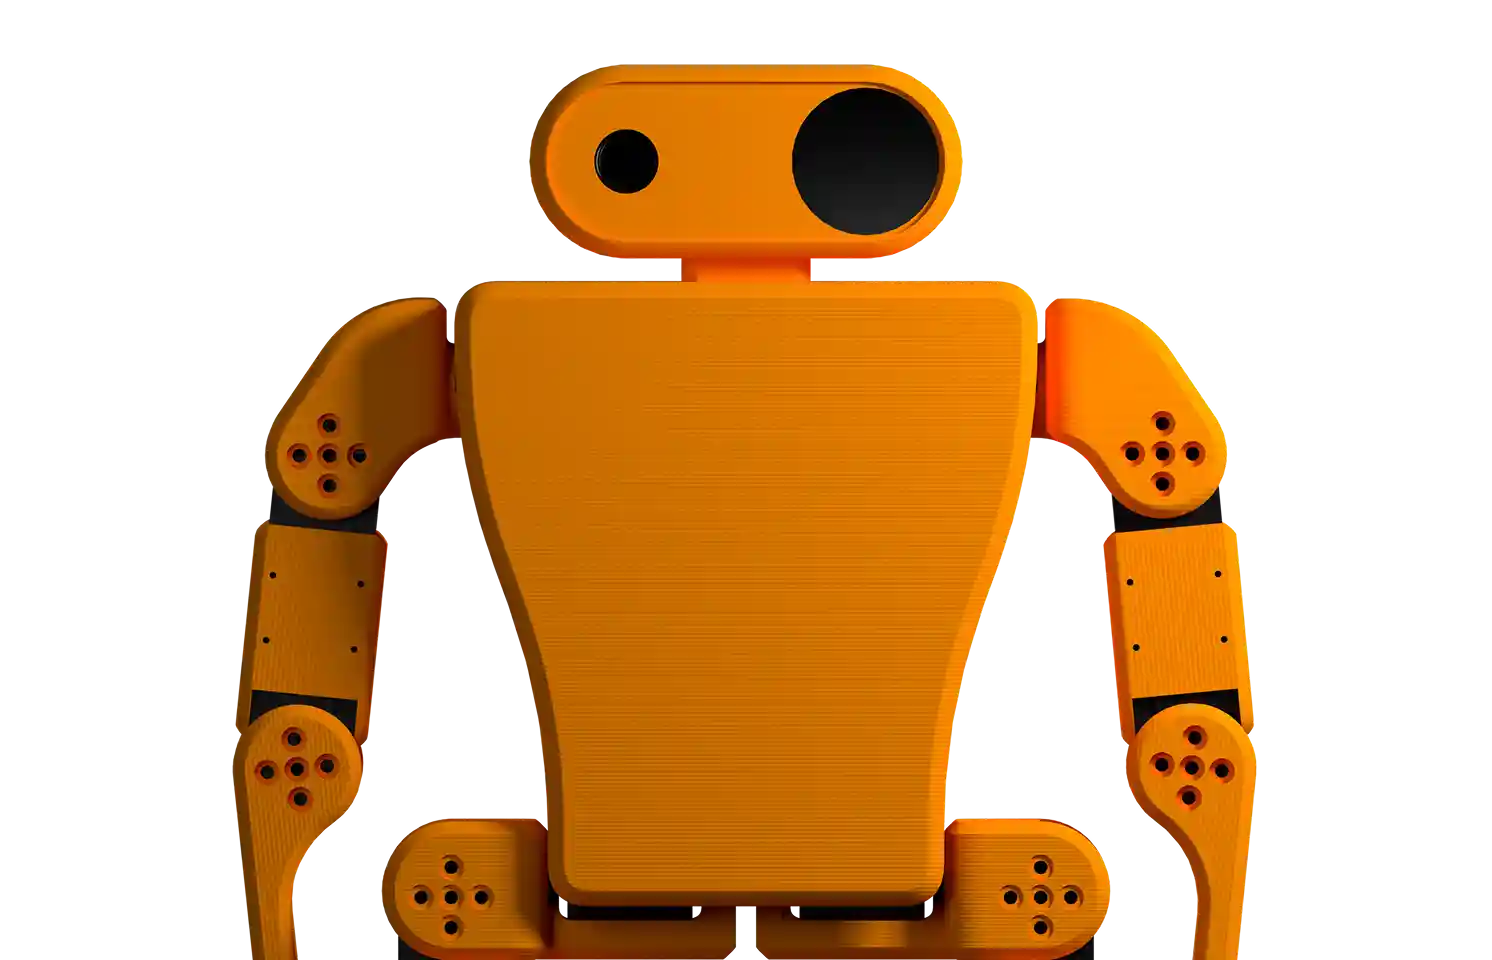 zeroth bot ↗$300 3d-printed humanoid, assembled at schools and hospitals 100+ times
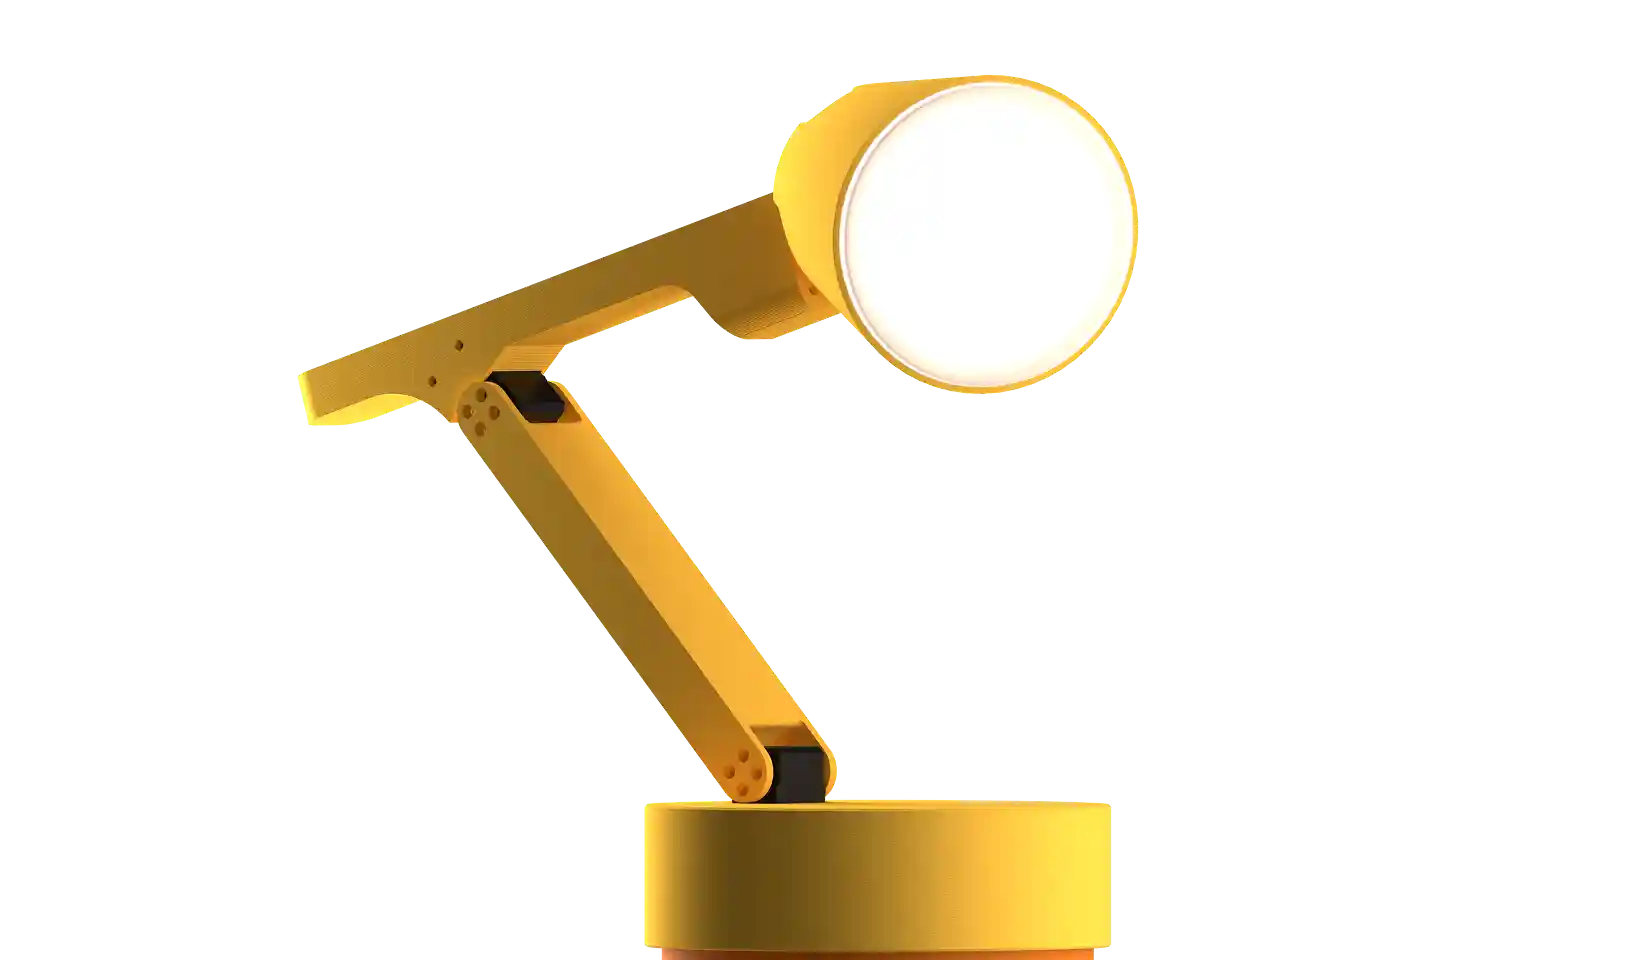 lelamp ↗Expressive 5-axis lamp for studying how people live with robots
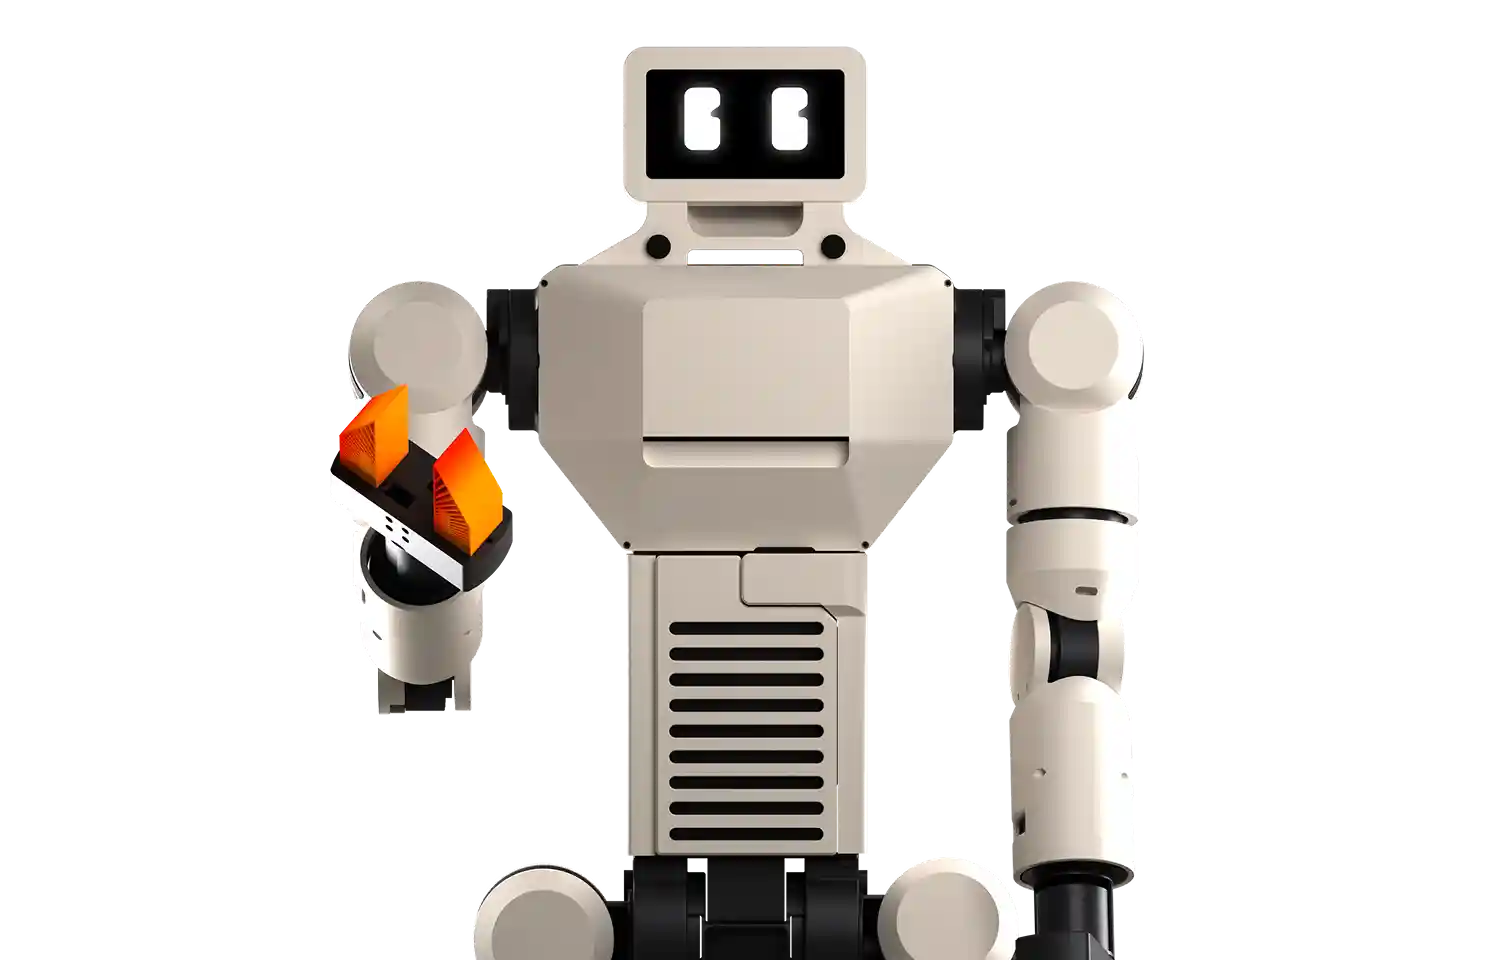 stompy ↗k-scale's first humanoid platform, where it all started
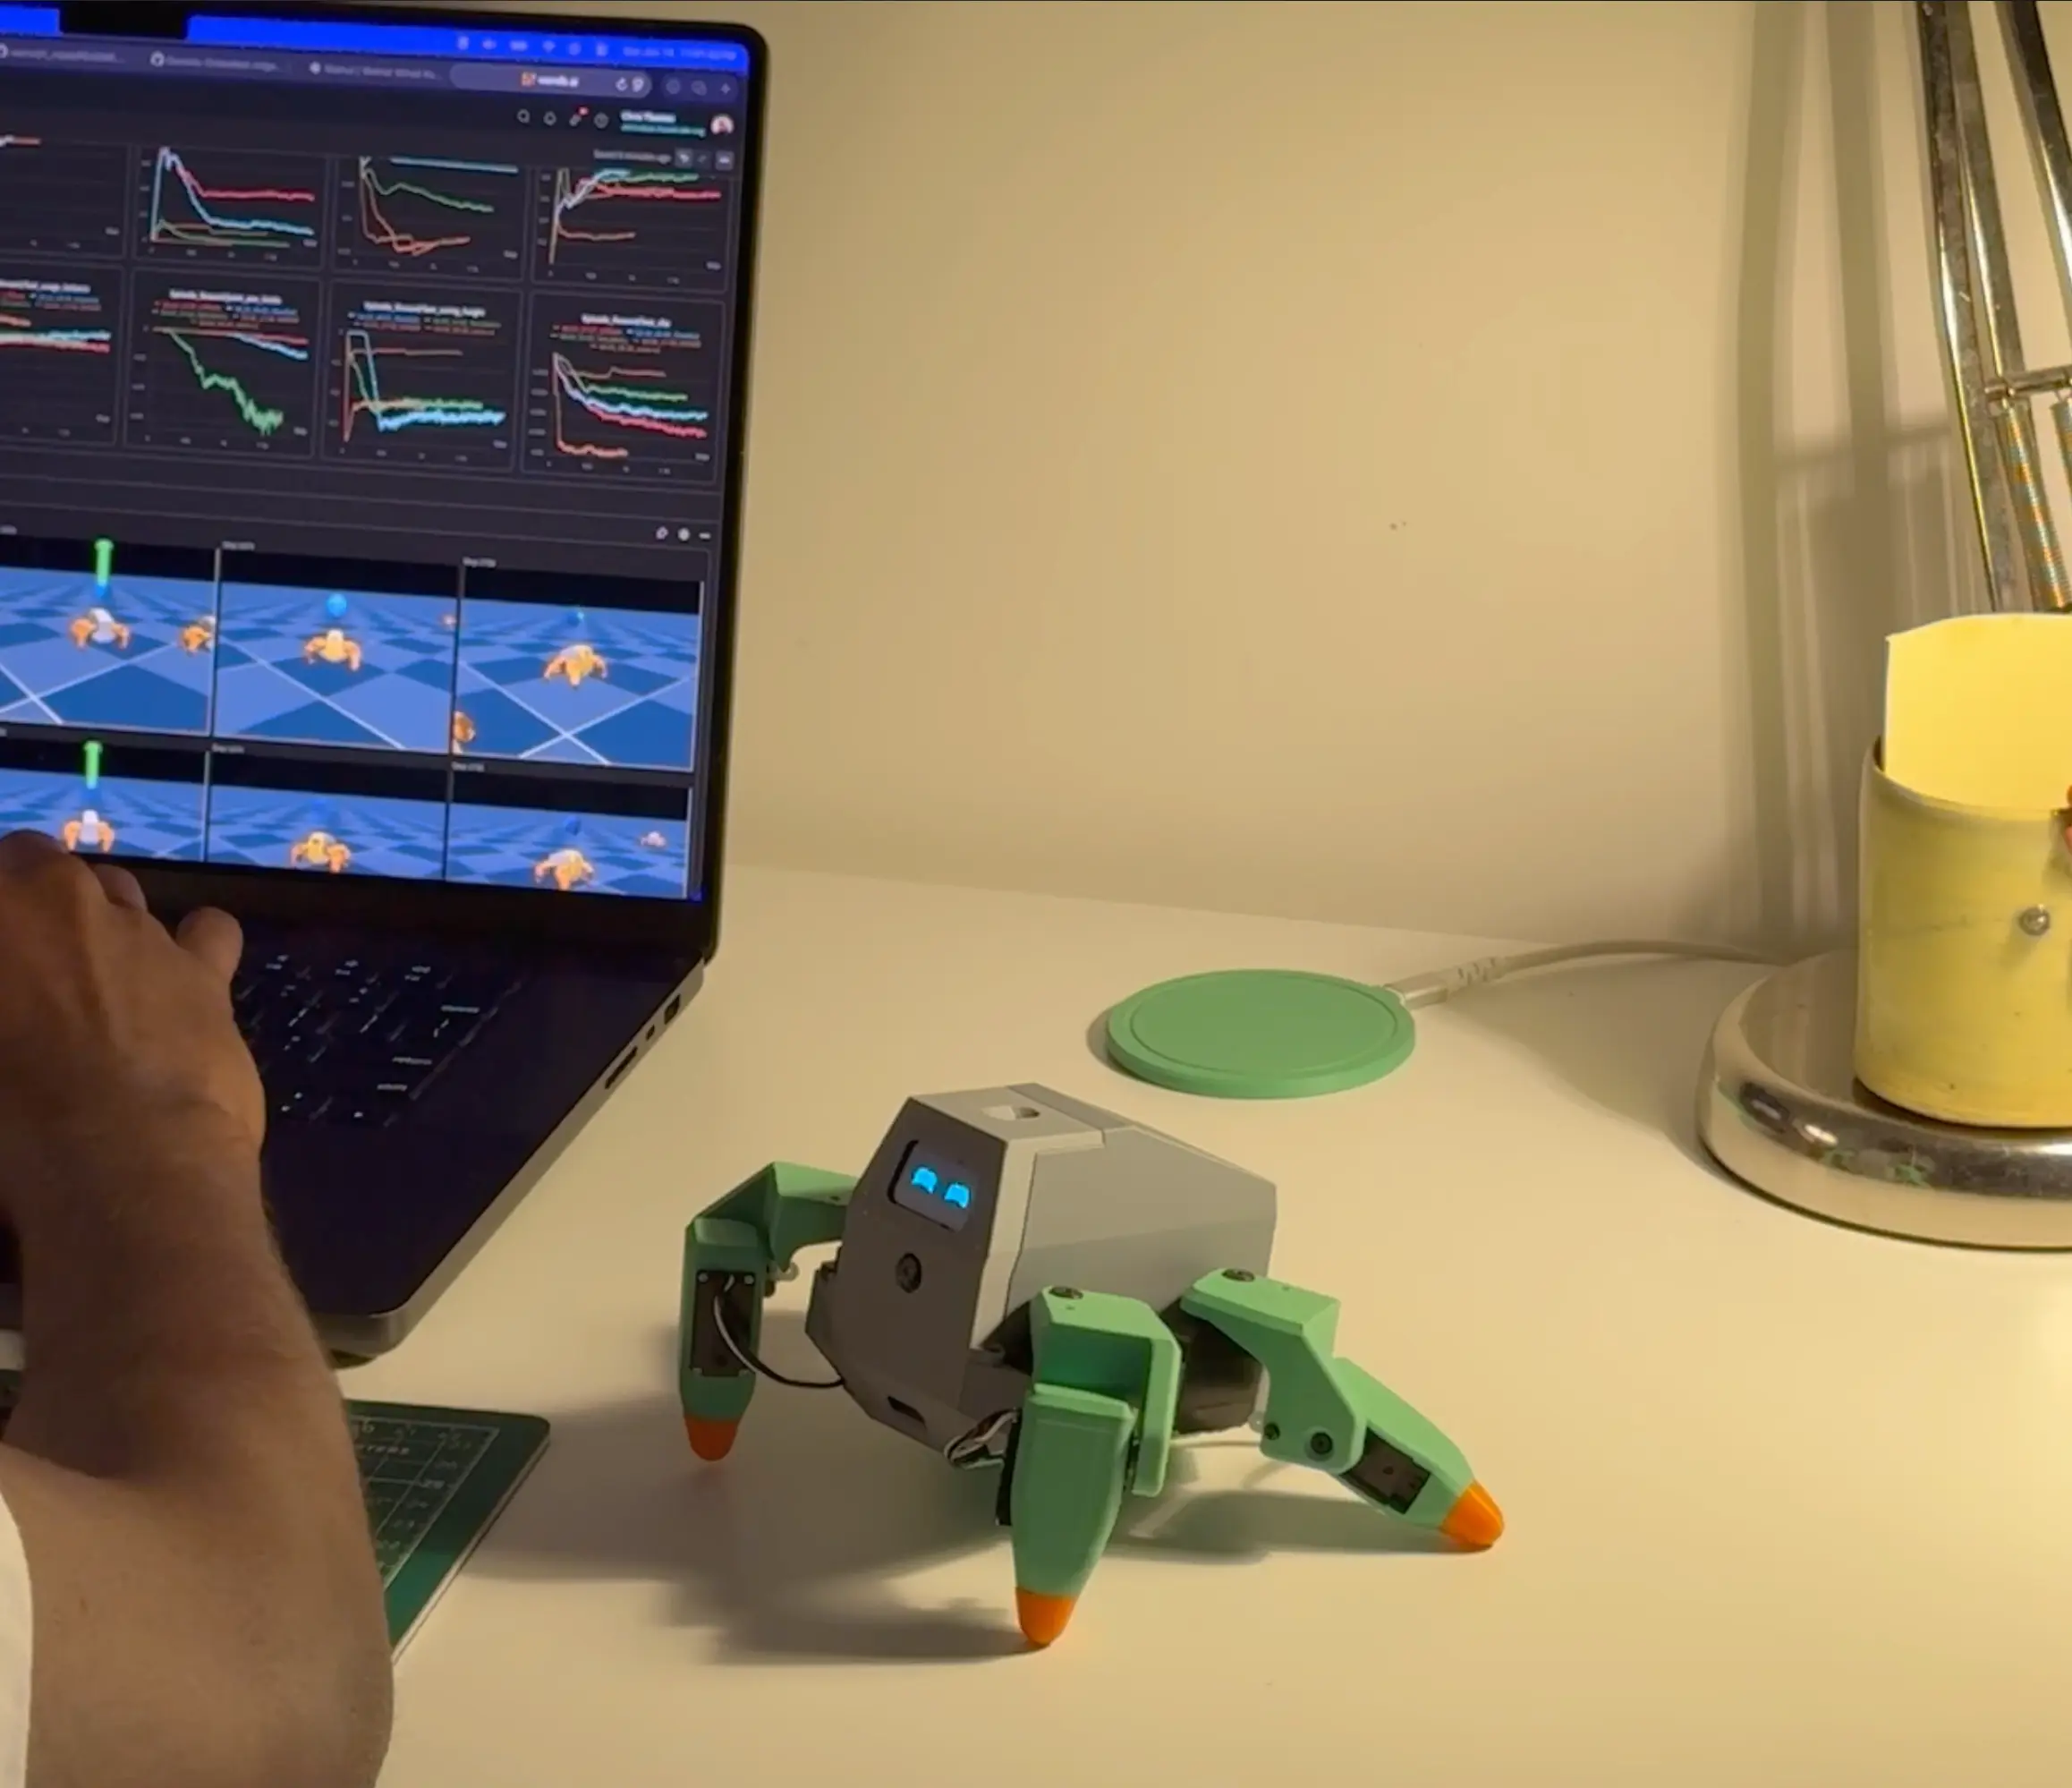 walnut ↗Sub-$100 quadruped running its PPO policy on an ESP32
— odds and ends